Cable-Driven Parallel Robot
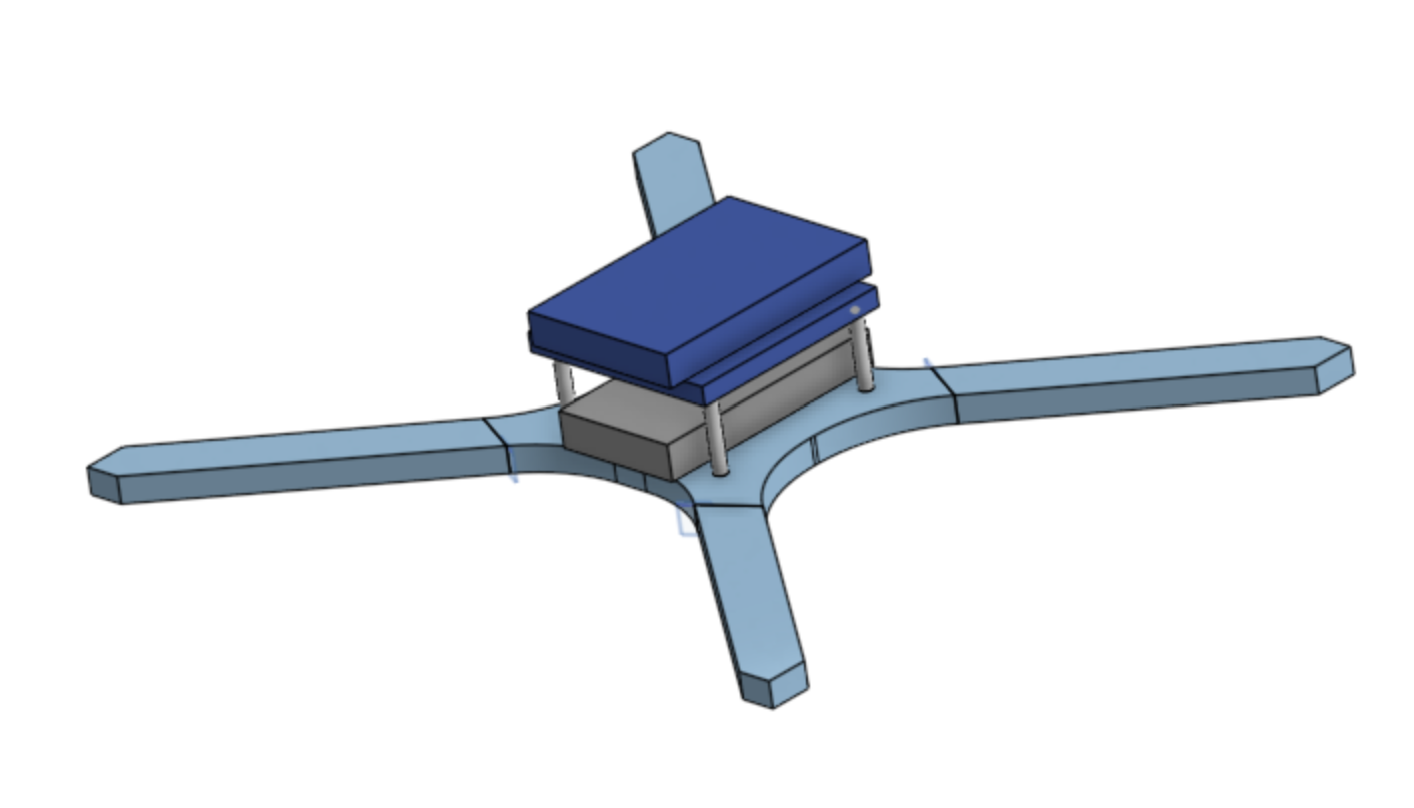
Led mechanical design efforts for a research robot, coordinating a team of 10+ students across attachment design, winch development, and system integration.
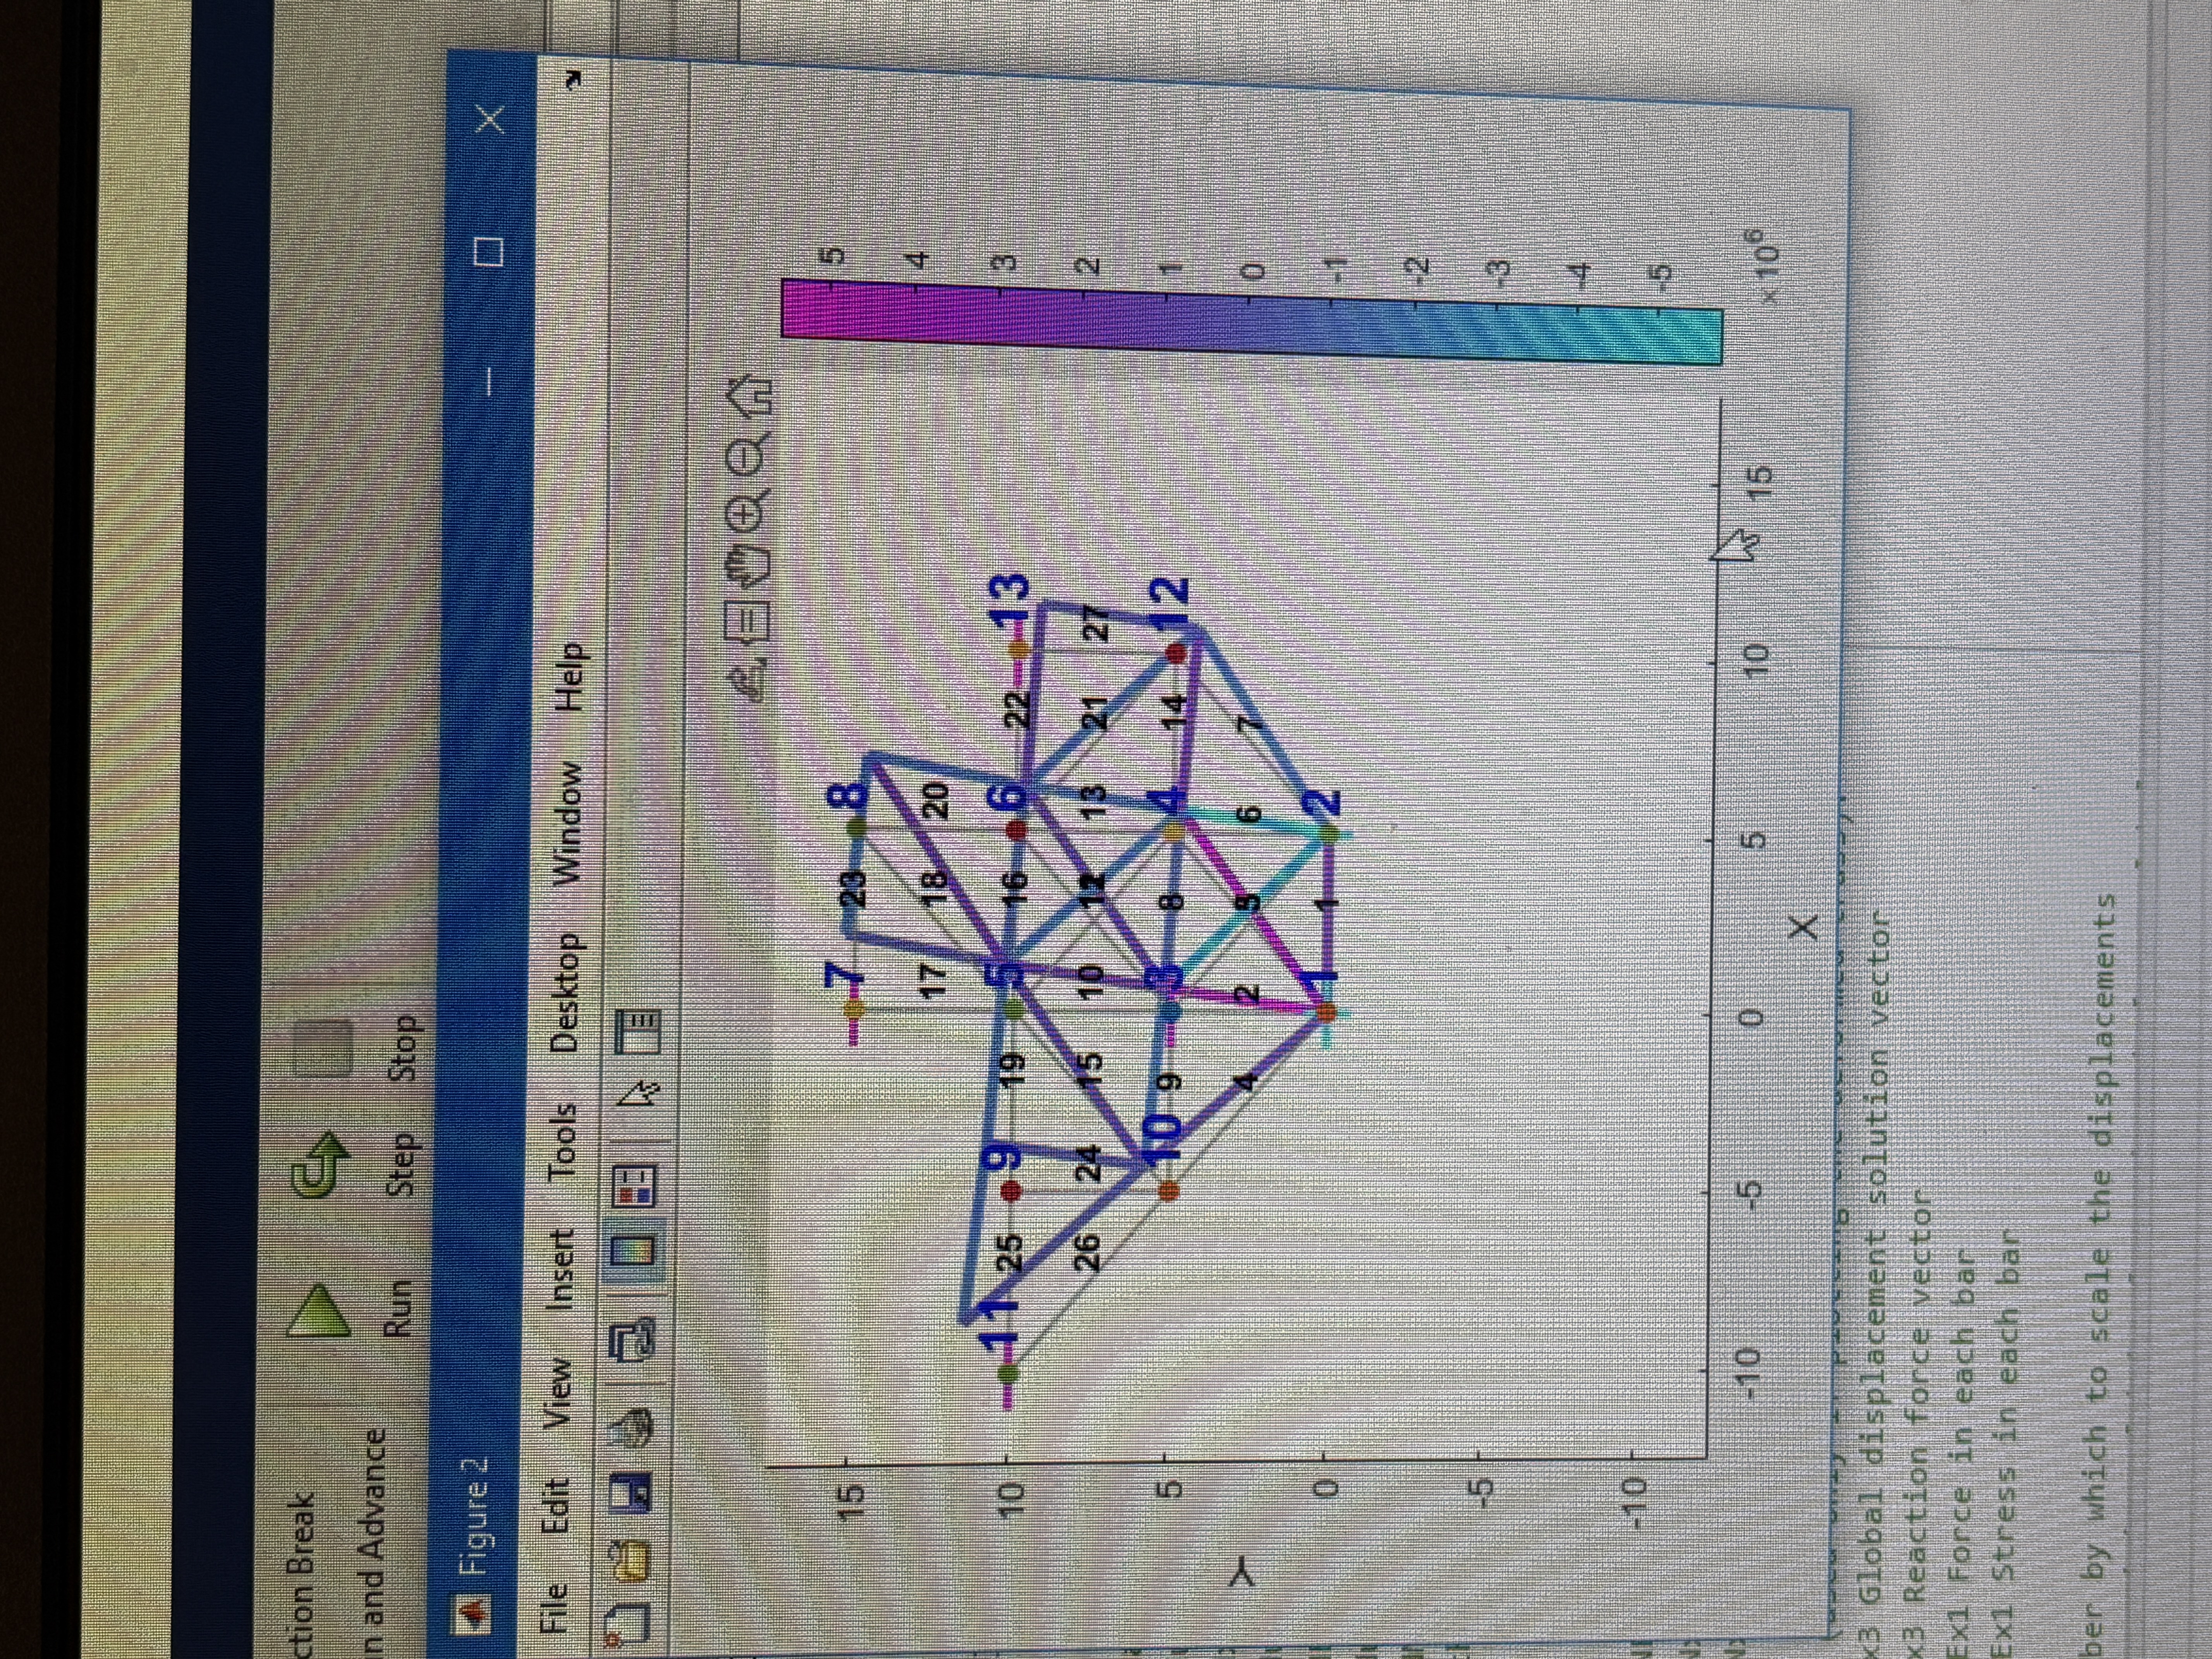
Redesigned an attachment to reduce its per-unit mass by 98%, and contributed to safety-factor analysis, inverse kinematics modeling, prototyping, and testing.